Have a look to the latest blog & news around you
We are excited to announce the acceptance of the article “Large Language Model-Based Robot Task Planning from Voice Command Transcriptions” at the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2025). This work was developed within euROBIN’s research activities on service robotics (WP2), focusing on enabling robots to perform domestic tasks from natural language instructions.
One of the central challenges in building a General Purpose Service Robot (GPSR) lies in interpreting human commands, which often contain speech recognition errors and incomplete information. This paper presents an end-to-end pipeline that leverages a Large Language Model (LLM) to directly translate instruction transcripts into coherent and context-aware action plans. By integrating environmental information into the input, the system is able to generate more efficient task executions.
Key highlights of the paper include:
-
An LLM-based approach to bridge natural language instructions and robot task planning
-
Integration of environmental context for improved efficiency
-
Validation through a simulator based on Generalized Stochastic Petri Nets, with a success rate of ~55% on the ALFRED dataset, including unseen environments
-
Successful real-world deployment at RoboCup 2024 in Eindhoven, achieving 2nd place in the GPSR task
You can access the full paper here: https://afonsocerto.com/files/iros2025_llm_robot_planning.pdf
Congratulations to the authors Afonso Certo, Bruno Martins, Carlos Azevedo, and Pedro U. Lima for this significant contribution to advancing natural language understanding in robotics!
We are proud to announce the publication of the article “A roadmap for AI in robotics” in the journal Nature Machine Intelligence — the result of collaborative work between the euROBIN Strategic Research Agenda (SRA) and leading academic voices in the robotics and AI communities.
This Perspective piece offers a comprehensive and thoughtful roadmap for the future of artificial intelligence in robotics. As excitement continues to grow around the potential of AI to address critical challenges in robotics, this publication takes a step back to ask: Which AI approaches are truly suited to the physical, interactive, and dynamic nature of robotics?
Unlike AI systems that analyze static data, robots must act and sense in complex real-world environments. The paper highlights how this adds layers of complexity — from adapting models to individual robot designs and physical tasks, to deploying AI across varied platforms and scenarios.
The authors examine:
-
The progress made in integrating AI into robotics since the 1990s
-
The need for updated and representative datasets for diverse robot tasks
-
How AI can be designed to generalize across platforms while being tailored to robotics-specific problems
-
The importance of explainability, transparency, and trust in human–robot interaction
-
The long-term goals of lifelong learning, safe deployment, and sustainable development
This article is not only a reflection of how far the field has come — it also serves as a strategic reference for the research and development roadmap being shaped within the euROBIN network and beyond.
You can access the full article here: https://www.nature.com/articles/s42256-025-01050-6
A huge thank you to the authors: Aude Billard, Alin Albu-Schaeffer, Michael Beetz, Wolfram Burgard, Peter Corke, Matei Ciocarlie, Ravinder Dahiya, Danica Kragic, Ken Goldberg, Yukie Nagai & Davide Scaramuzza — and to all contributors involved in this milestone work.
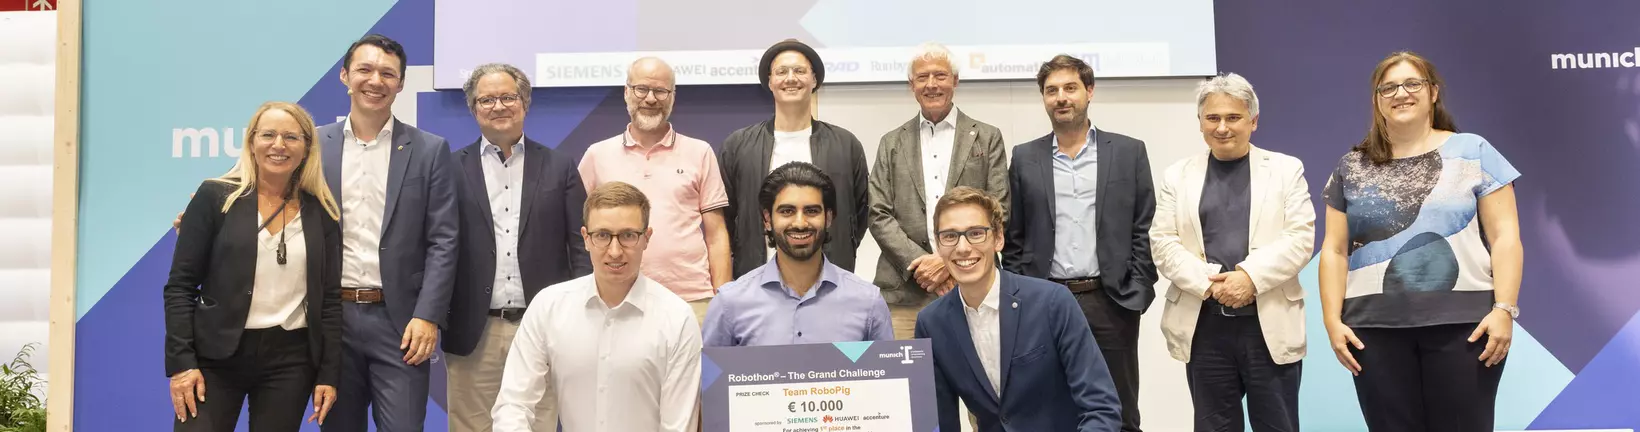
Call for teams! Robothon® – The Grand Challenge Series is back again for its fourth edition ahead of the automatica trade show. International teams can apply with their own robotic platform to prove their skills, be discovered, win prize money up to €10,000 sponsored by Yaskawa and the euROBIN Project and shape the future of robotics in science and industry by working on a real-world problem!
Apply now!! (extended deadline ONLY a few days): Apply here
Robothon® is an international competition to develop skills in robot manipulation as part of the high-tech platform munich_i from the Munich Institute of Robotics and Machine Intelligence (MIRMI) of the Technical University of Munich (TUM), in collaboration with Messe München and automatica. This event brings together the world's outstanding thought leaders and personalities from AI and robotics.
munich_i will take place again at the next automatica from June 24-27, 2025, in Munich. The distributed competition will take place ahead of the trade show where teams can compete from their own labs during a 30-day period beginning in April.
Learn more on the Event Website: www.robothon-grand-challenge.com